David Hardman

David Hardman

Robotics JRF

University of Cambridge

Biography

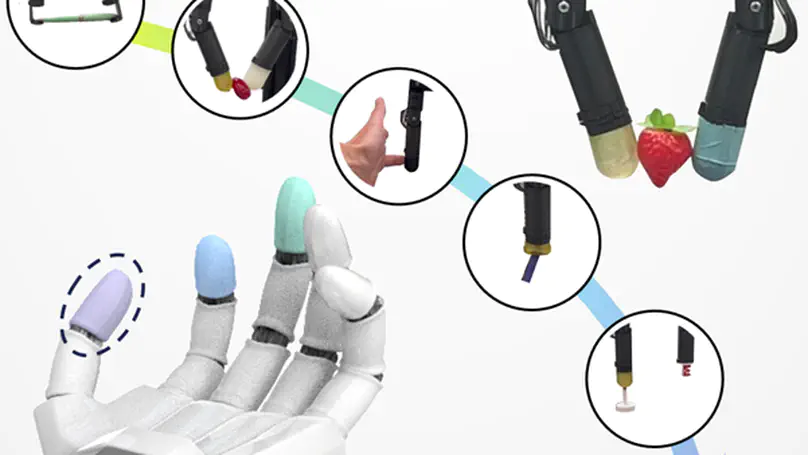
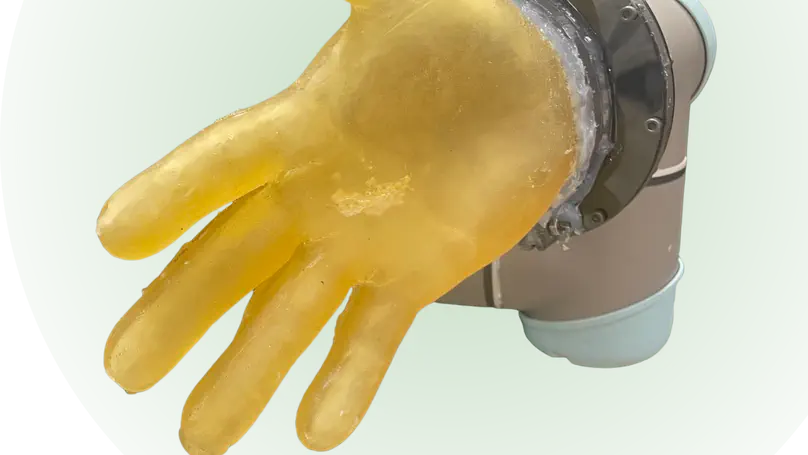
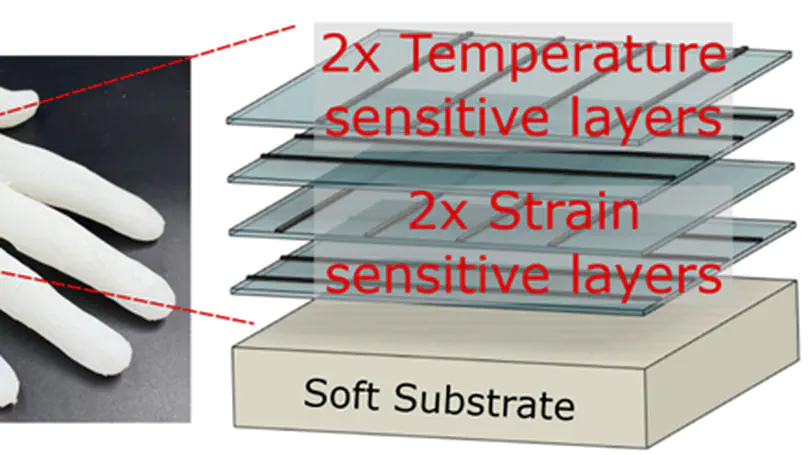
I’m a Henslow Junior Research Fellow (JRF) in robotics at Fitzwilliam College, Cambridge. Most of my days are spent building tactile sensors and soft robots in Cambridge’s Bio-Inspired Robotics Laboratory, where I am an affiliated lecturer, Fellow of the Higher Education Academy (FHEA), and recently held an EPSRC Doctoral Prize Fellowship.

During my PhD I also worked as a visiting researcher in EPFL’s CREATE Lab, and in TTP’s surgical team. Outside of work I enjoy playing badminton and tennis, and I’m a member of the world-famous Magic Circle.

You can watch a video about some of my research here.

Interests
  • Mechatronics & soft robotics
  • Tactile perception & artificial skins
  • Medical automation
  • Additive manufacturing
  • Large-scale experimentation
Education
  • PhD in Bio-Inspired Robotics, 2020-2024

    University of Cambridge

  • MEng in Mechanics, Materials and Design, 2019-2020

    University of Cambridge

  • BA in Engineering, 2016-2019

    University of Cambridge

Experience


Fitzwilliam College, Cambridge
Junior Research Fellow
Oct 2024 – Present Cambridge


Department of Engineering
Affiliated Lecturer
Oct 2025 – Present University of Cambridge


Bio-Inspired Robotics Laboratory
EPSRC Doctoral Prize Fellow
Oct 2024 – Mar 2026 University of Cambridge


Computational Robot Design & Fabrication Lab
Visiting Researcher
Jun 2024 – Sep 2024 EPFL


Bio-Inspired Robotics Laboratory
PhD Student
Oct 2020 – Jun 2024 University of Cambridge


The Technology Partnership
Consultant (Health Tech)
Mar 2023 – Jun 2023 Cambridge


Cambridge Centre for International Research
Teaching Assistant
Jun 2021 – Jul 2022 Cambridge


Bio-Inspired Robotics Laboratory
Undergraduate Researcher
Jul 2019 – Sep 2019 University of Cambridge

Publications

(2026). Non-destructive classification of root vegetable dimensions and varieties. In Comput. Electron. Agric...

PDF Cite DOI

(2026). Roadmap on sustainable soft robotics by additive manufacturing. In Smart Mater. Struct..

PDF Cite

(2026). Economy of Touch - Task-Driven Information Selection in Tactile EIT-based Robotic Sensing. In Adv. Intell. Syst..

PDF Cite

(2026). Touch with Insight - Physics-Aware Data-Driven Learning for EIT-Based Tactile Sensing. In ICRA 2026.

PDF Cite

(2026). The Language of Deformation - Semantic Failure Analysis as a Prerequisite for Dexterous Manipulation of Deformable Objects. In ERF 2026.

PDF Cite

Contact